AI vision-guided motor rehabilitation robot
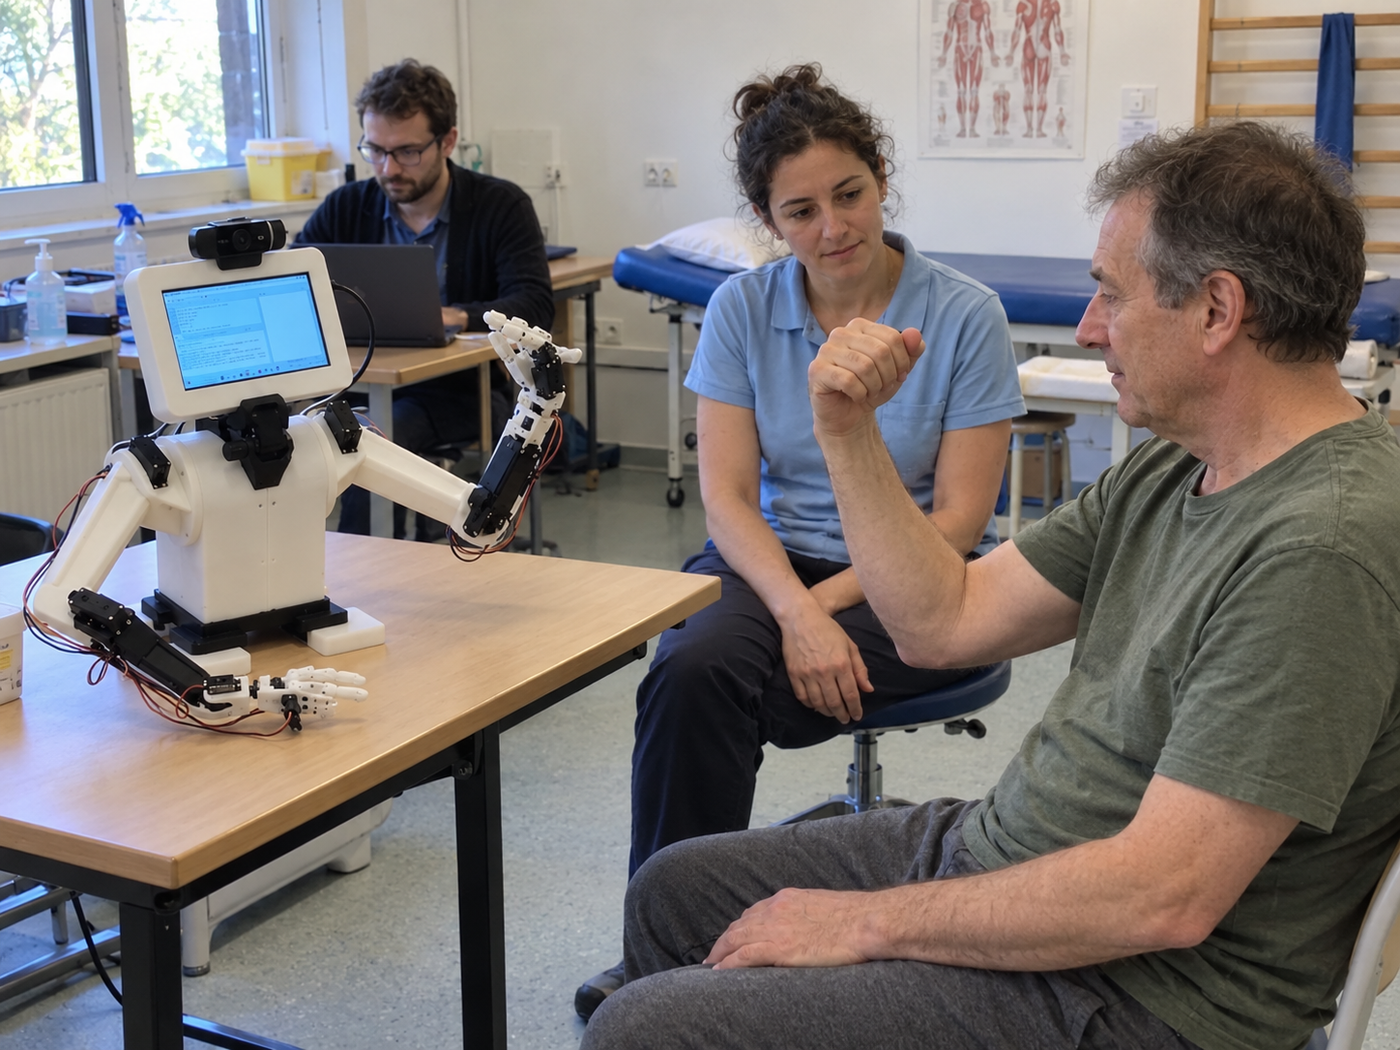
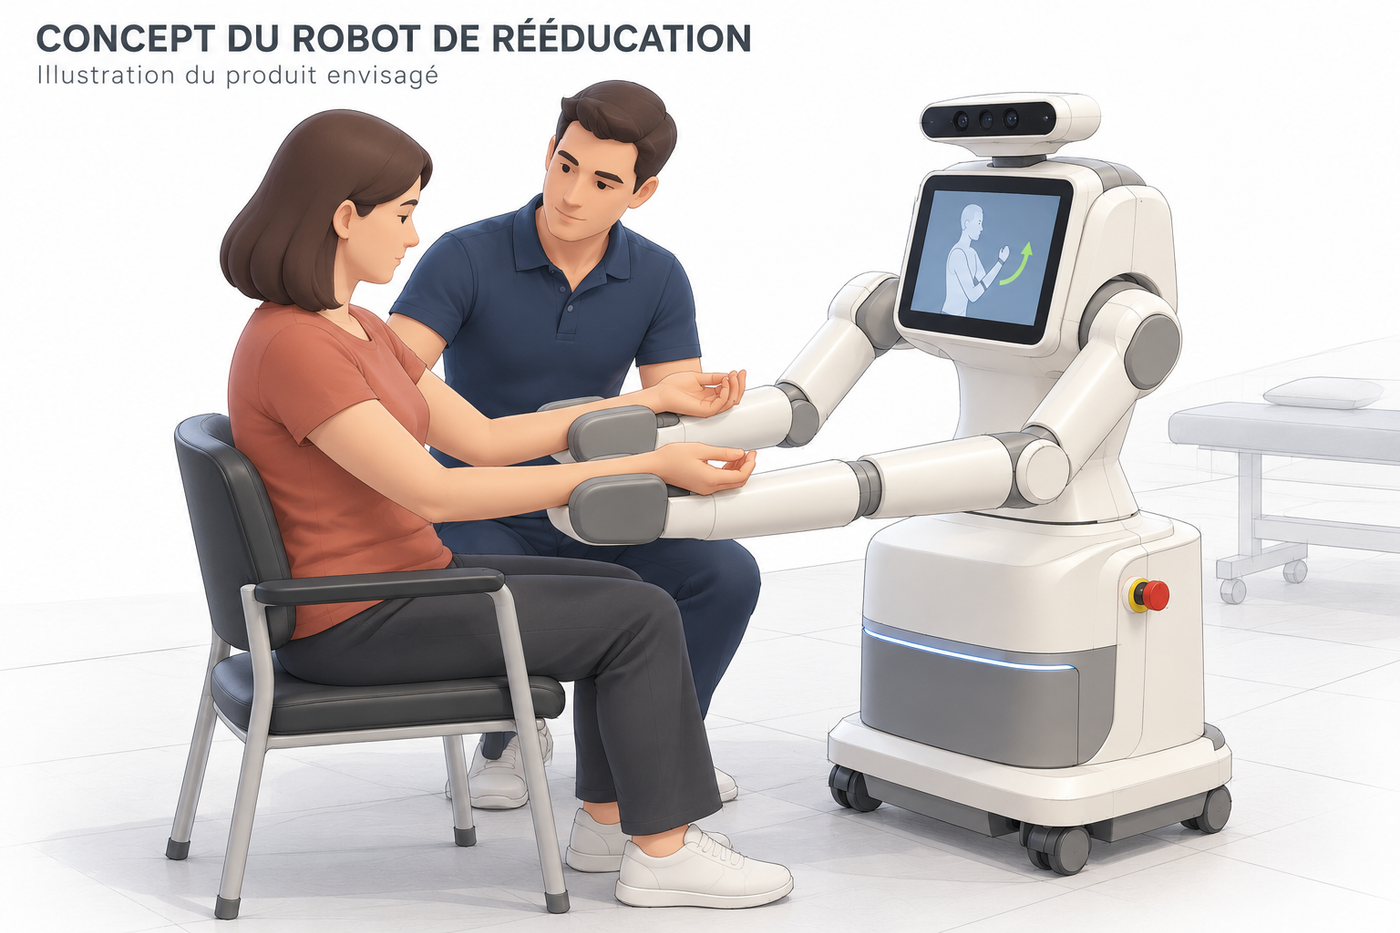
A robot that learns the therapist's movement and reproduces it to guide the patient.
96,5 %Joint-angle extraction accuracy
−40 %Movement errors vs. unsupervised exercise
78 %Sessions run without human intervention
90 %Users satisfied with ease of use
THE CHALLENGE
Motor rehabilitation relies on regular, precise repetition of exercises. Its effectiveness depends on constant supervision by a physiotherapist — a scarce and costly resource, especially in remote areas. Without supervision, movement errors increase and treatment consistency drops.
OUR SOLUTION
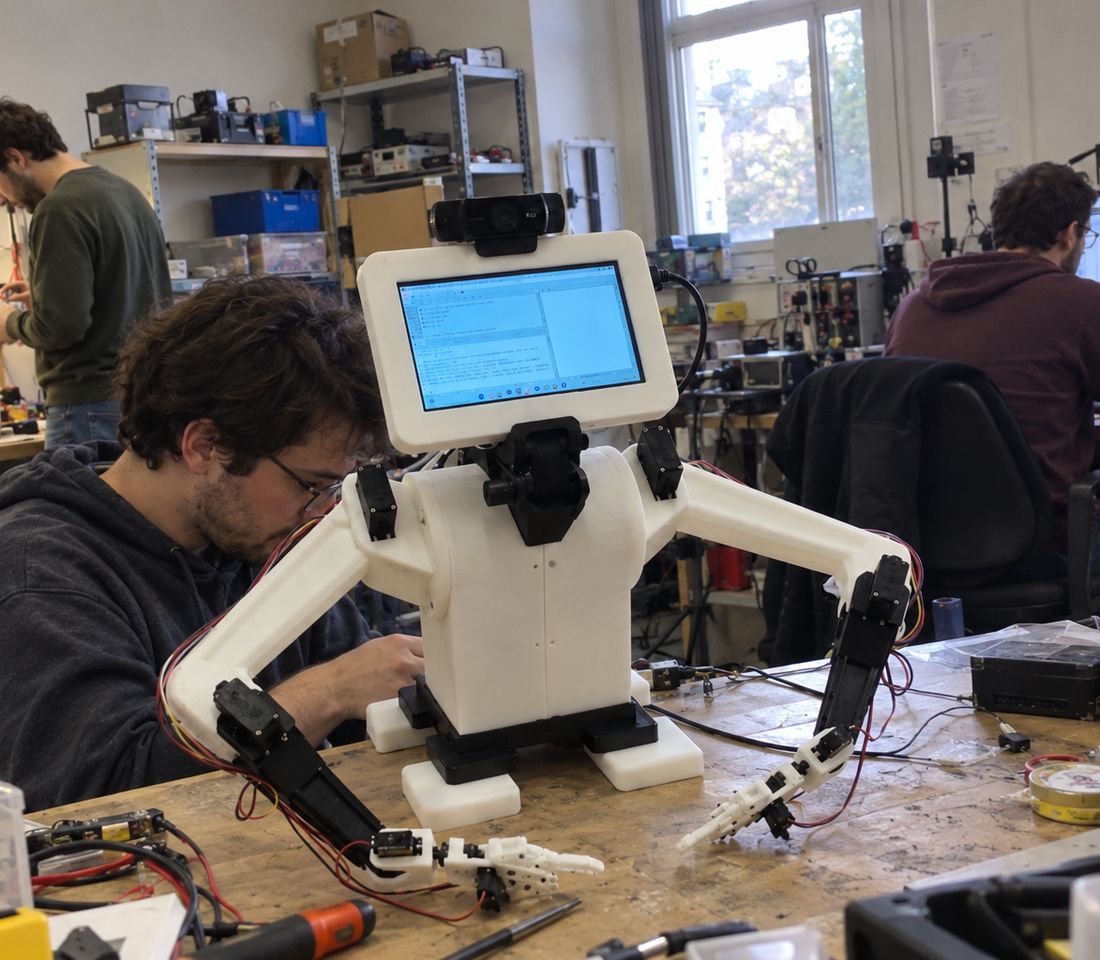
The therapist performs the exercise once in front of the camera. Computer vision algorithms extract shoulder, elbow and wrist angles, then the two-arm robot replays the sequence identically — same order, rhythm and range — to guide the patient independently, within adapted safety limits.
HOW IT WORKS
- 01Video captureThe therapist performs the exercise in front of a 1080p camera.
- 02AI vision analysisJoint detection and angle computation frame by frame.
- 03RecordingAngles and timing stored to build an exercise library.
- 04Robotic playbackThe robot replays the exercise with limited range and speed.
TECHNICAL SPECIFICATIONS
| Structure | 3D-printed PLA |
|---|---|
| Weight | ≈ 1.5 kg — tabletop |
| Kinematics | 2 arms · 3 joints each |
| Range | Up to 180° |
| Actuators | Servo motors |
| Control | Arduino Uno · USB link |
| Vision | 1080p camera |
TECHNOLOGIES
PythonOpenCVMediaPipeArduinoFusion 360Impression 3D
TECHNOLOGY READINESSTRL 4 — Validated in the lab4 / 9
SAFETY
- Range limits per joint
- Speed adapted to the patient
- Immediate stop on anomaly
GALLERY
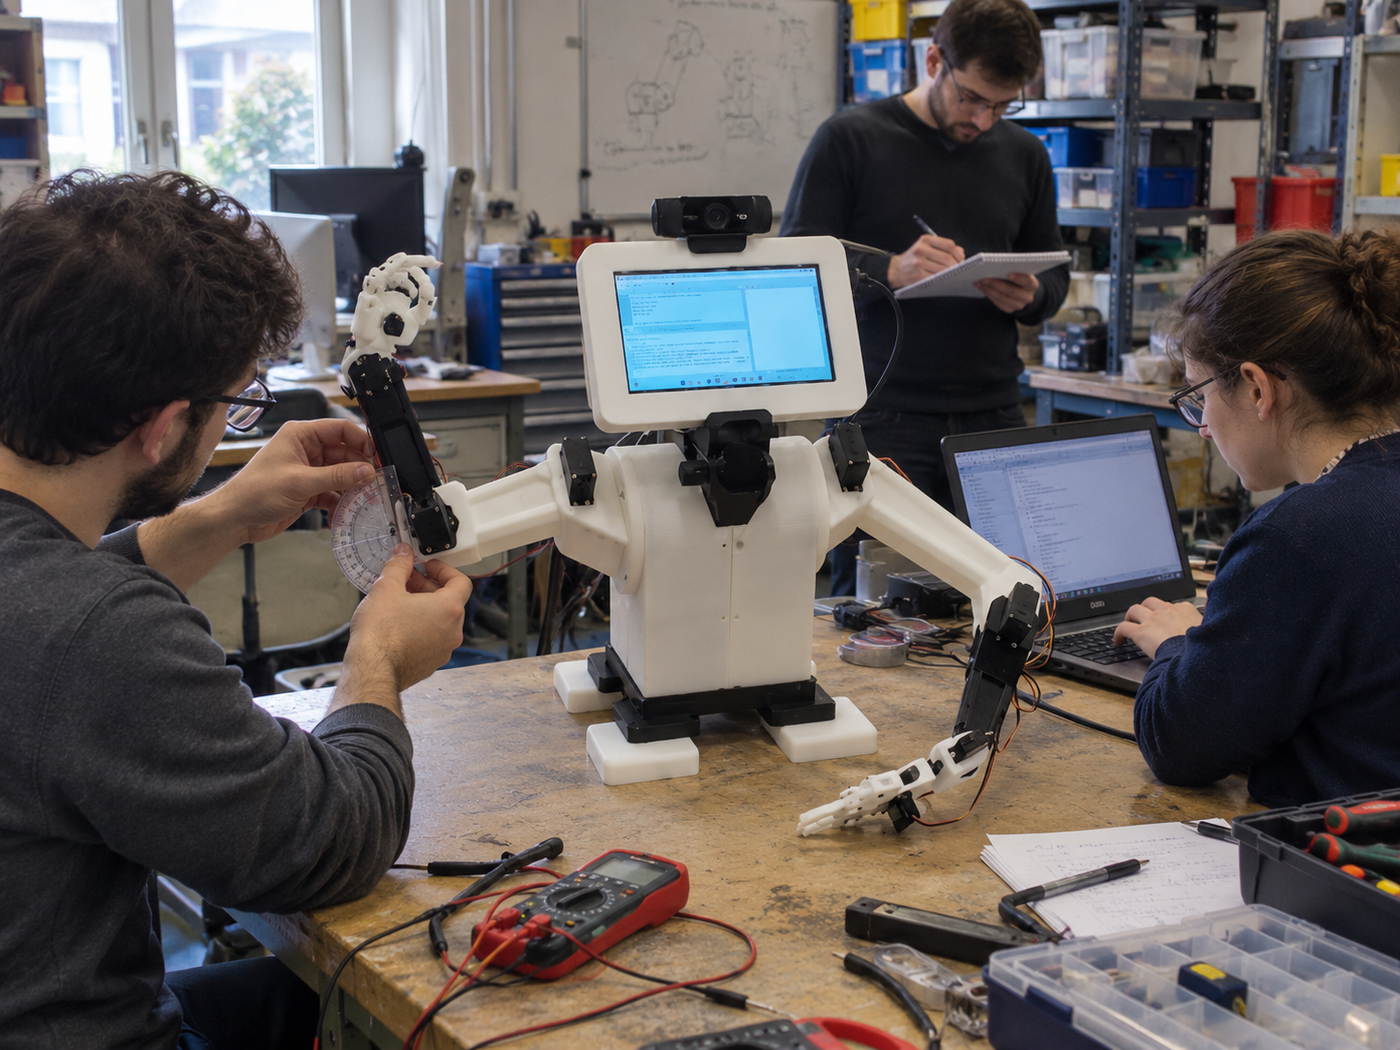
The project in pictures
OUTLOOK
Next steps
- Extension to neck, back and lower limbs
- Automatic patient assessment and reports for practitioners
- Remote monitoring through a telemedicine platform
- Compact version for home use
Interested in this prototype?
Partnership, further testing or industrialisation with C2S Engineering: let's talk.